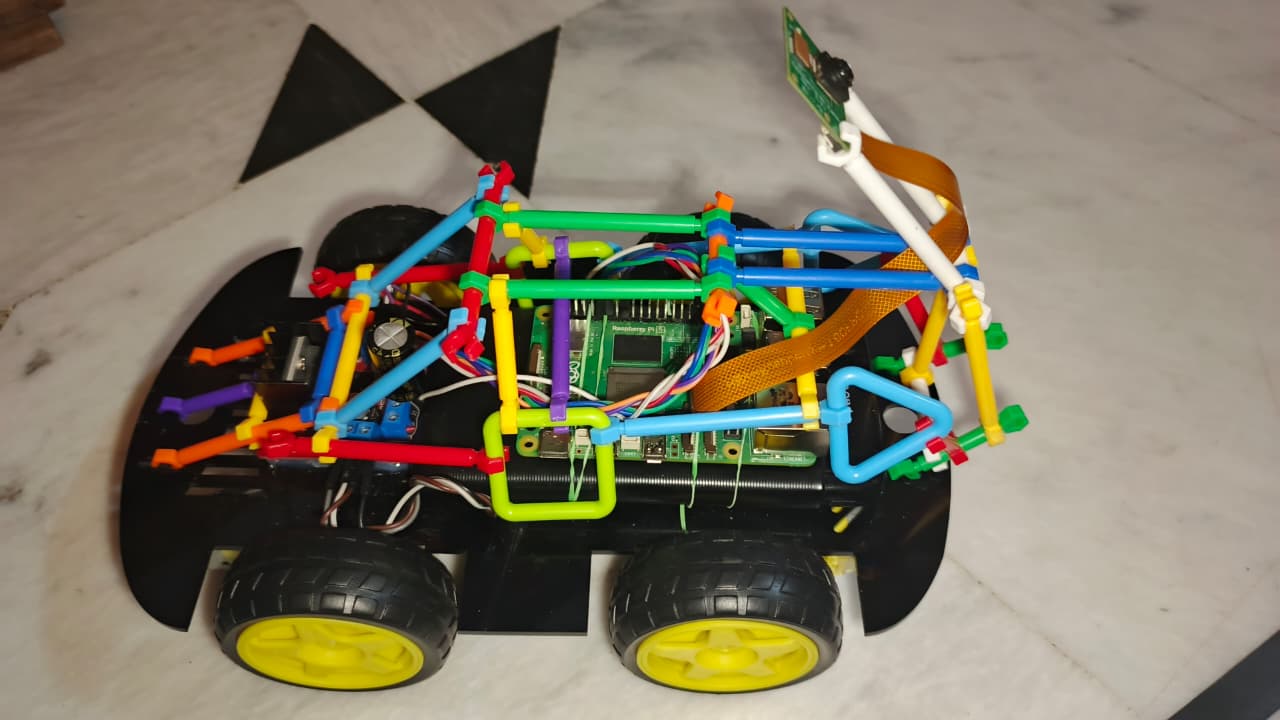
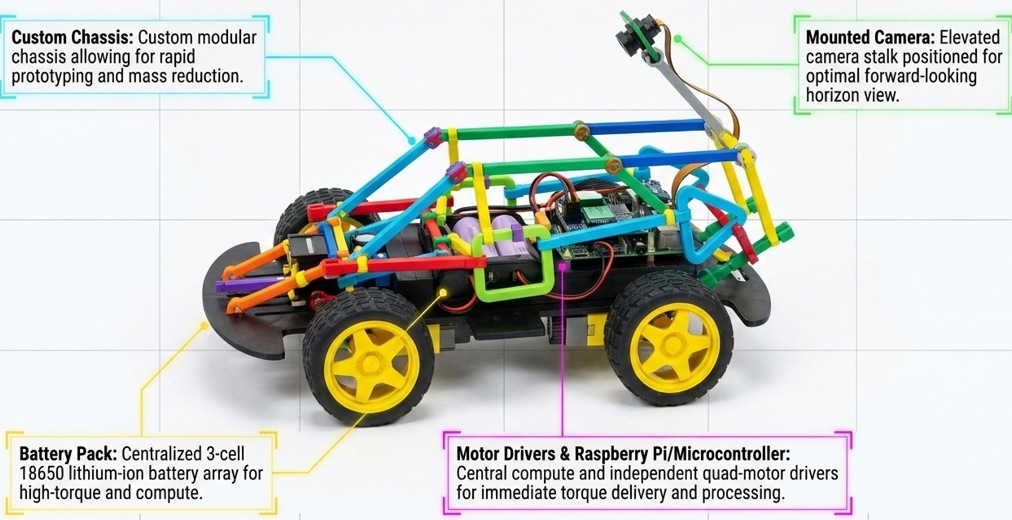
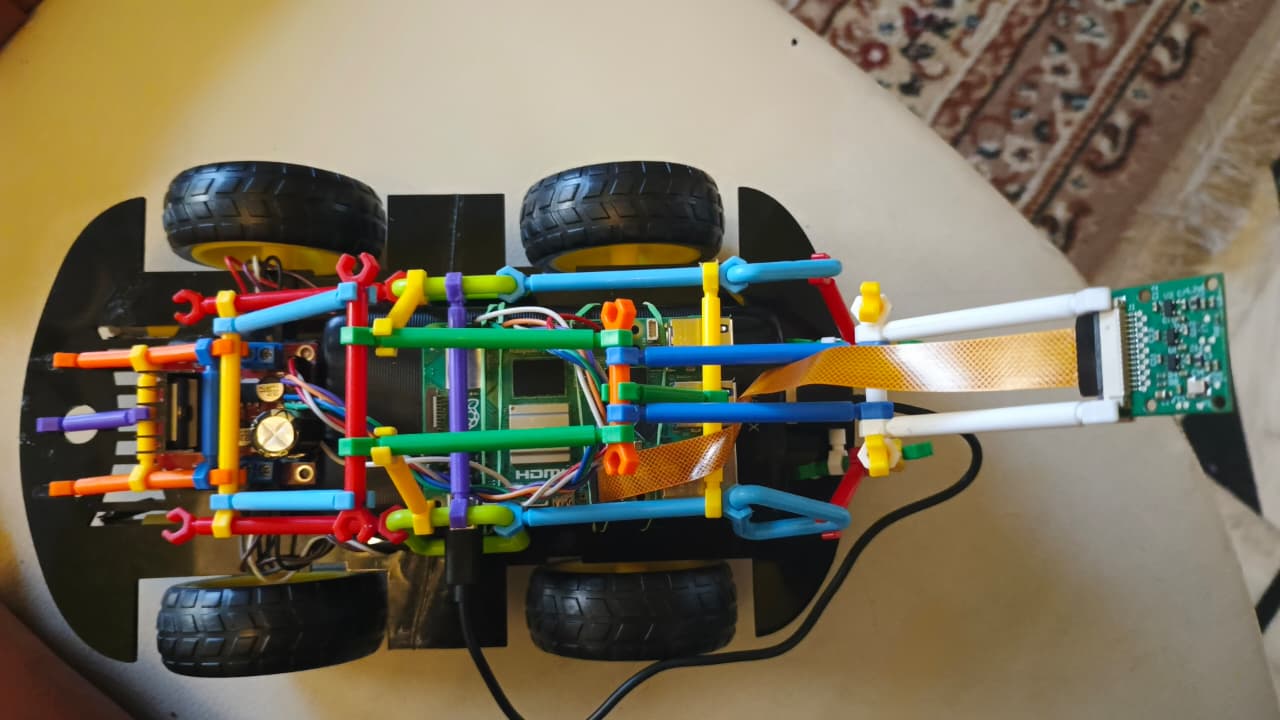
An end-to-end TinyML racing car that maps camera frames to steering commands while balancing model accuracy against real-time control latency.
RP2040TFLite MicroPilotNetINT8
Overview
The physical platform combines a modified 1:24 RC chassis, camera, Raspberry Pi Pico / RP2040 deployment path, and PWM steering control. A PilotNet-style convolutional neural network turns raw camera frames directly into steering-angle commands.
Optimization
Training starts with Udacity simulator data and is fine-tuned on physical-track captures. INT8 quantization and depthwise separable convolutions reduce resource use and latency; a hardware-aware search evaluated 720 architectures against the 133 ms real-time target.
Results
Latency-aware model selection proved more effective than accuracy alone: the report’s joint-optimal model completed 9 laps versus 5 for a marginally more accurate but slower alternative.