Overview
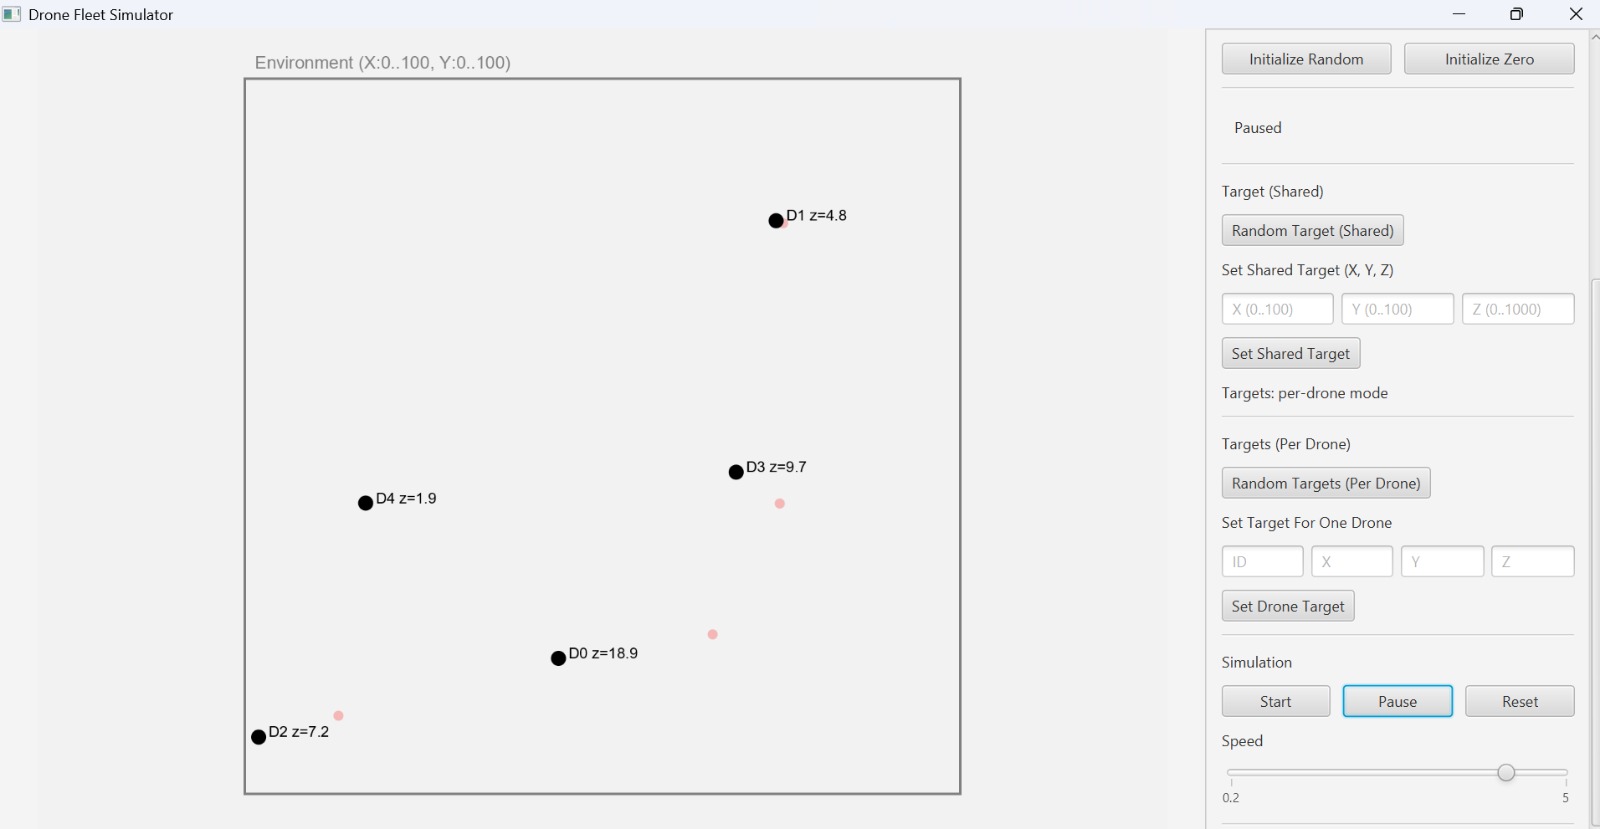
Each drone is modelled as an autonomous agent with its own dynamics, controller, communication state, and collision response. The simulation makes multi-drone experiments repeatable without the risk and cost of hardware testing.
Project / Software
A JavaFX simulator for coordinated quadrotor agents, designed to safely evaluate navigation, formation control, communication, and collision avoidance.
JavaJavaFXOOPSimulation
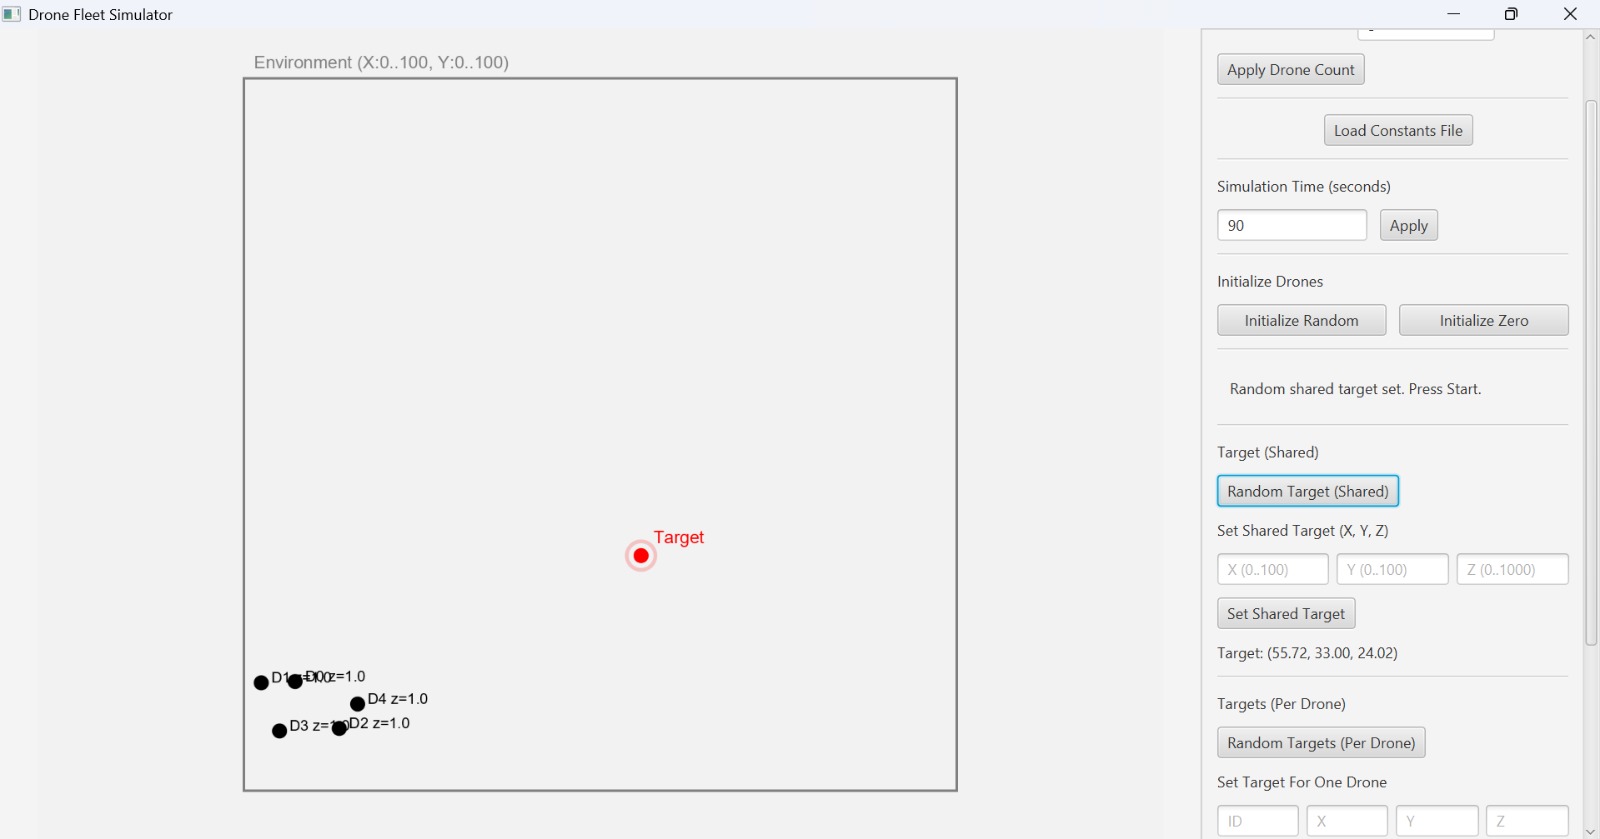
Each drone is modelled as an autonomous agent with its own dynamics, controller, communication state, and collision response. The simulation makes multi-drone experiments repeatable without the risk and cost of hardware testing.
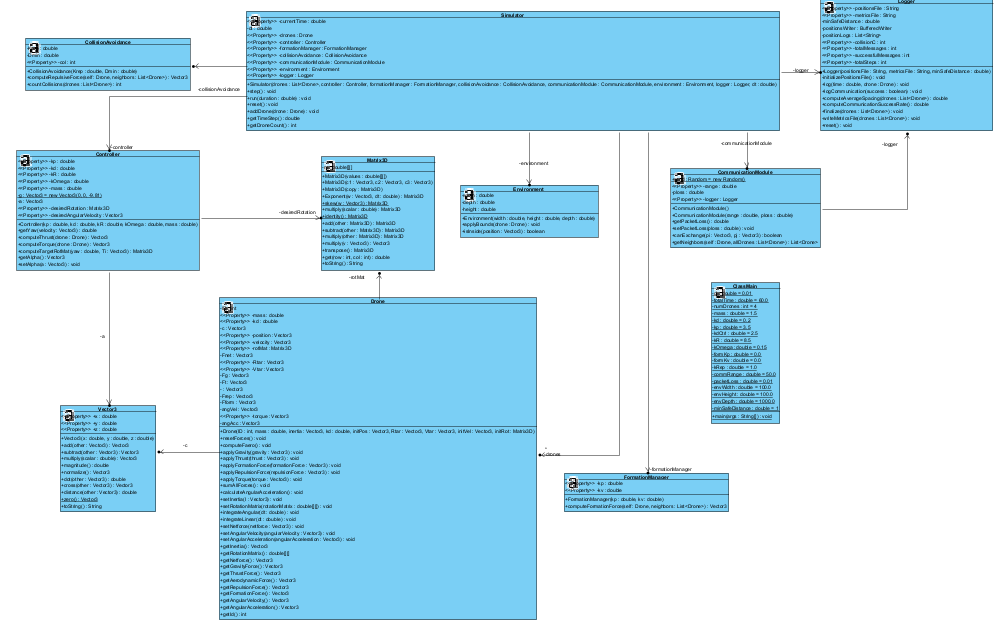
The object-oriented design separates 3D mathematics, drone dynamics, PD control, formation forces, collision avoidance, communication, visualization, and logging. A discrete-time Euler update advances the state, records position data, and presents real-time motion in the JavaFX interface.
The project demonstrated stable target convergence, safe inter-drone spacing, and observable communication effects. CSV position logs and metrics files support post-run analysis.
A recorded run of the Autonomous Drone Fleet Coordination Simulator.